About Me
About Me
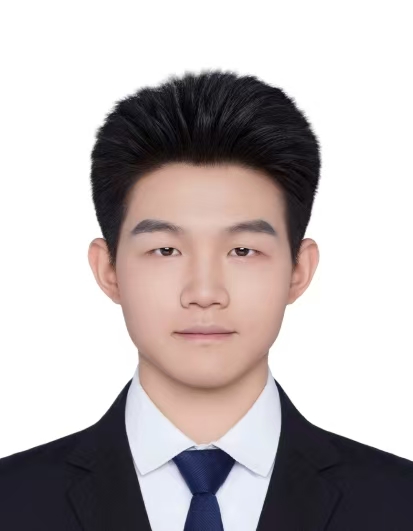
I am Yuanjiang Xue, an MSc student in Computer Control & Automation at the School of Electrical and Electronic Engineering (EEE), Nanyang Technological University, Singapore. My research is in embodied AI — building robots that perceive, reason and act in the physical world rather than only in simulation or on static datasets.
The thread running through my work is contact. Most manipulation systems reason about geometry — where things are, how to reach them — and treat the forces that arise on contact as a disturbance to be rejected. I am interested in the opposite premise: that a policy should predict what contact its actions will produce, learn from the difference, and let human effort and data collection concentrate on the moments where contact actually decides the outcome. That premise runs through all four directions below — representation, reasoning, data, and the human in the loop.
Research Interests
- Embodied Foundation Models & VLA — large-scale multimodal manipulation policies, and RL post-training that grounds them in real interaction outcomes instead of offline likelihood
- Contact-Rich & Force-Aware Manipulation — wrench-conditioned policies, sub-millimeter assembly, compliant interaction, tactile sensing
- Sample-Efficient Real-World RL — human-in-the-loop learning that spends scarce human intervention where it carries the most information
- Agentic Manipulation & Embodied Reasoning — structured scene representations that keep semantic task planning aligned with geometric and physical constraints, with failure diagnosis and recovery
- Dexterous Teleoperation & Shared Autonomy — bimanual dexterous control with ego-centric perception and force feedback, as an interface for collecting contact-rich data
Research
Full list on the publications page and my Google Scholar profile.
Facet-0 — Making contact a prediction target
A Robotic Foundation Model for Contact-Rich Precise Manipulation. arXiv:2609.01596, 2026.
Sub-millimeter assembly fails in ways that pure vision cannot see: two motions can look equally close to task completion while one is quietly jamming the part. Facet-0 makes the wrench a first-class prediction target alongside the action — flow matching generates each action chunk together with the wrist-wrench profile that chunk is expected to induce, on top of a representation that aligns causal wrench history with vision-language semantics and kinematic state. RL post-training then learns a distributional Action-Wrench Critic that separates motions with similar task progress but different contact outcomes, while phase-aware rewards and contact-selective credit concentrate policy improvement on the decisive interactions. Trained on ManuFacet-1K, a 1,000-hour force-synchronized corpus spanning three embodiments, it reaches 82% mean success on five sub-millimeter assembly tasks against 15% for the strongest baseline, at 0.5 mm placement accuracy and 50 ms command latency.
UniManip — Keeping plans and geometry aligned
General-Purpose Zero-Shot Robotic Manipulation with Agentic Operational Graph. arXiv:2602.13086, 2026. Project page
Zero-shot generalization breaks from two opposite directions: end-to-end VLA models lack the precision for long-horizon tasks, while hierarchical planners are semantically rigid the moment the world stops matching their assumptions. UniManip bridges them with a bi-level Agentic Operational Graph — an Agentic Layer orchestrating the task above a Scene Layer holding dynamic, object-centric state — and continuously re-aligns the abstract plan against live geometric constraints. It runs as a loop rather than a pipeline: instantiate scene graphs from unstructured perception, parameterize them into collision-free trajectories through a safety-aware local planner, then use structured memory to diagnose failures and recover autonomously. It beats state-of-the-art VLA and hierarchical baselines by 22.5% and 25.0% success rate, and transfers zero-shot from fixed-base to mobile manipulation with no fine-tuning or reconfiguration.
DexTeleop-0 — Closing the embodiment gap with touch
Force-Aware Bimanual Dexterous Teleoperation with Ego-Centric Perception towards Shared Autonomy. arXiv:2606.23431, 2026.
Contact-rich data is the bottleneck for embodied learning, and teleoperation is how we collect it — but the embodiment gap blocks accurate kinematic mapping from human to robot, and tactile and force feedback are usually absent entirely. DexTeleop-0 adds a tactile-driven adaptation layer on top of an existing teleoperation pipeline: a real-time optimization loop estimates accurate contact points, reads a tactile-enabled fingertip force-sensing profile, and computes localized corrections through the operational space Jacobian with respect to joint-angle updates. The operator supplies coarse intent; the loop turns it into precise, force-compliant commands. Evaluated in simulation and on real hardware, it improves success rate and execution efficiency on robust grasping, disturbance-resilient manipulation, and complex dexterous tasks.
E2HiL — Spending human attention where it counts
Entropy-Guided Sample Selection for Efficient Real-World Human-in-the-Loop Reinforcement Learning. IEEE Robotics and Automation Letters (RA-L), 2026. arXiv:2601.19969 · Project page
Human-in-the-loop RL makes real-world manipulation trainable, but converges only after a great many human interventions — the labor cost is the real limit. E2HiL starts from the observation that a stable reduction of policy entropy, not merely a fast one, is what buys a good exploration-exploitation trade-off. It builds influence functions measuring each sample’s effect on policy entropy — estimated efficiently from the covariance of action probabilities and soft advantages — and then keeps only samples of moderate influence, pruning both shortcut samples that cause sharp entropy collapse and noisy samples with negligible effect. Across 10 real-world manipulation tasks spanning multiple embodiments and learning frameworks, it improves success rate by 24.9% while reducing human interventions by 9.3% against state-of-the-art baselines, as a policy- and embodiment-agnostic plug-and-play module.
Before NTU
My earlier work was in imaging, signal processing and embedded hardware — background that still shapes how I think about sensing, noise and real-world systems.
- Image Processing Engineer, TP-Link Technologies (Jul–Nov 2023) — infrared night-vision algorithm optimization and wide-dynamic-range noise reduction for PTZ security cameras
- Hardware Development Engineer, Suzhou Sifei Technology (Dec 2023–Jun 2024) — MSPM0-series chip learning boards and EVM development
- Event Camera-Based Visual Microphone (invention patent) — reconstructing vibration signals from laser speckle event streams via event-point statistics
- Passive Radar CFAR Detection (invention patent) — adaptive time-slotted clutter map detection for complex environments
- Self-Developed UAV (bachelor thesis) — structural design, hardware assembly and flight control
Skills
- Programming: Python, C/C++, Java
- Robot Learning: PyTorch, reinforcement learning, imitation learning, real-robot deployment
- Platforms & Tools: Linux, Windows, Matlab, Solidworks
Contact
Reach me at E250086@e.ntu.edu.sg, or find me on Google Scholar and GitHub.